Encoders
SICK ARS60-ADA32768 Sensor
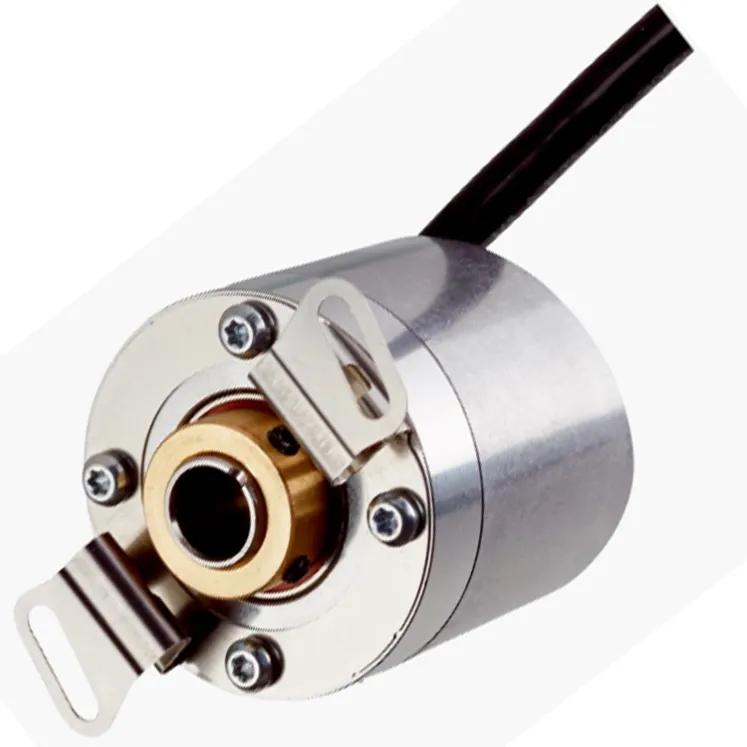
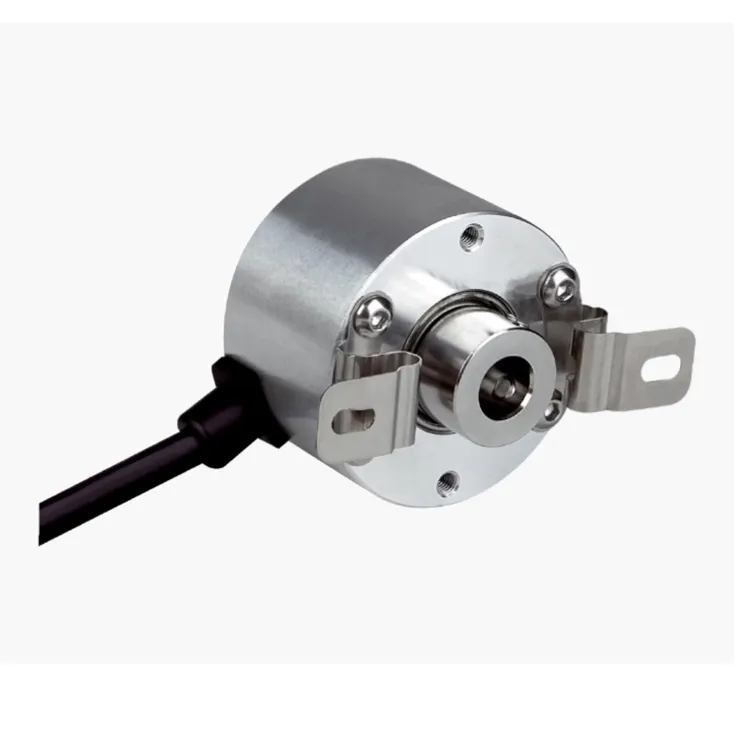
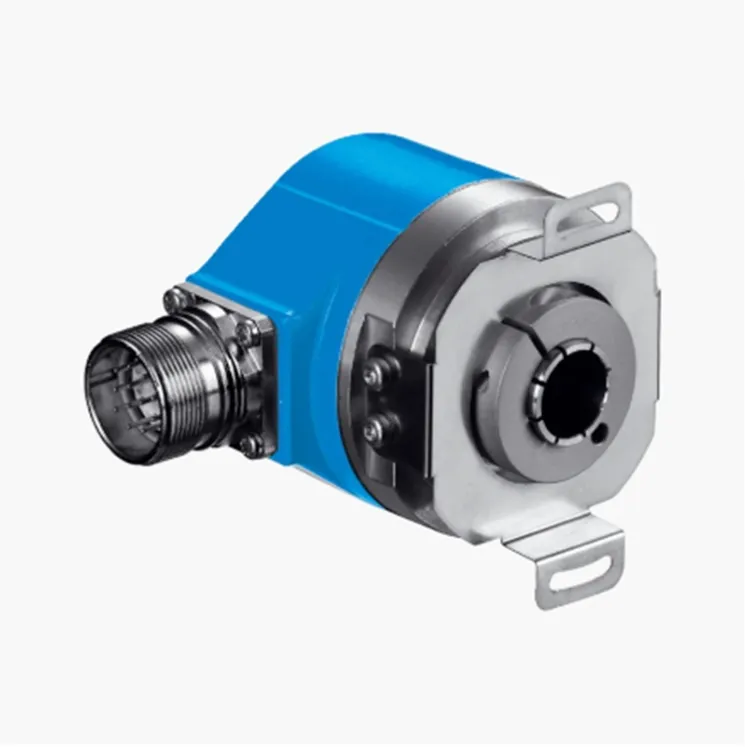
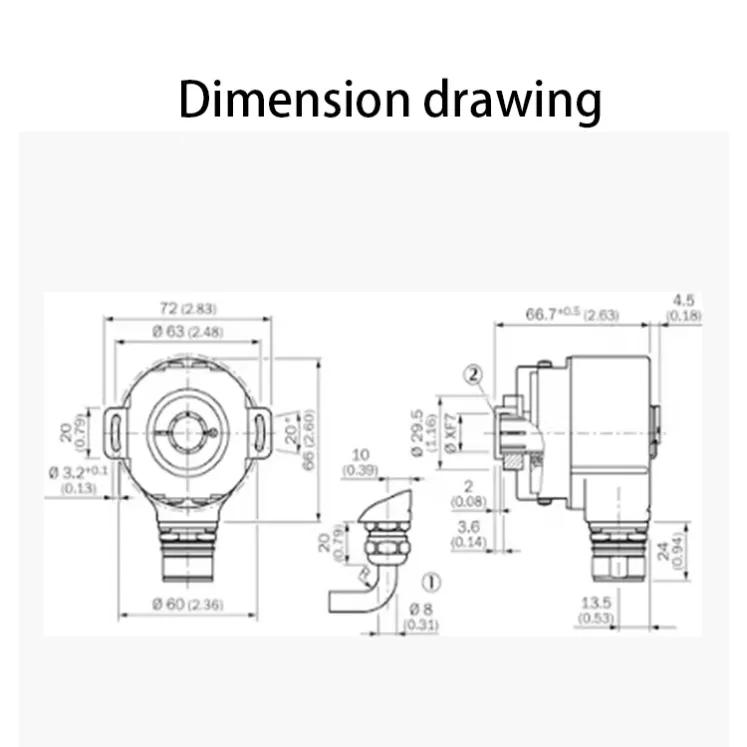
SICK ARS60-ADA32768 hollow-shaft rotary encoder. 15 mm through bore, 32768 pulses per revolution for direct motor feedback.
Overview
The SICK ARS60-ADA32768 is a rotary encoder with a 15 mm through hollow shaft from the ARS60 family. Mounted directly onto the motor or machine shaft, it converts rotation into high-resolution position feedback, with 32768 pulses per revolution as indicated by the order code.
How It Works
The optical scanning system senses the shaft rotation and produces incremental pulses per revolution. The drive controller counts these pulses and derives speed and relative position. The hollow-shaft design mounts over the motor shaft, eliminating the coupling and its alignment effort.
Key Features
- 15 mm through hollow shaft for direct motor mounting
- 32768 pulses per revolution (order code)
- No coupling required, compact axial length
- High-resolution optical scanning
- Reliable speed and position feedback
- Rugged housing for drive environments
Typical Applications
- Motor feedback on geared and servo motors
- Speed feedback on induction motor drives
- Position feedback on hoists and traverse axes
- Feedback on turntables and rotary feeders
- Retrofit feedback on existing motor shafts
Specifications
Attribute | Value |
|---|---|
Model | SICK ARS60-ADA32768 |
Encoder type | Rotary encoder, through hollow shaft |
Shaft bore | 15 mm hollow shaft |
Pulses per revolution | 32768 (order code) |
Installation and Setup Notes
Slide the encoder onto the shaft and fix it with the recommended torque anchor; avoid hammering or axial shock. Verify that the shaft runs within the family's axial and radial runout limits. Configure the drive counter input for the pulse count and check the direction of rotation.
Frequently Asked Questions
What is the advantage of a hollow shaft?
Direct shaft mounting removes the coupling, shortens the axial length and avoids alignment errors.
Does it lose position at power-down?
As an incremental design, position is relative; for absolute values use the AFS/AFM absolute families.
What does ADA32768 mean?
The suffix identifies interface and the 32768 pulses per revolution of this variant.
Related Encoders
For absolute feedback, see the SICK AFS60A-S4NB262144. For solid-shaft incremental encoders, see the SICK DBS60E-BGAC02048.